
PRODUCT TECHNOLOGY
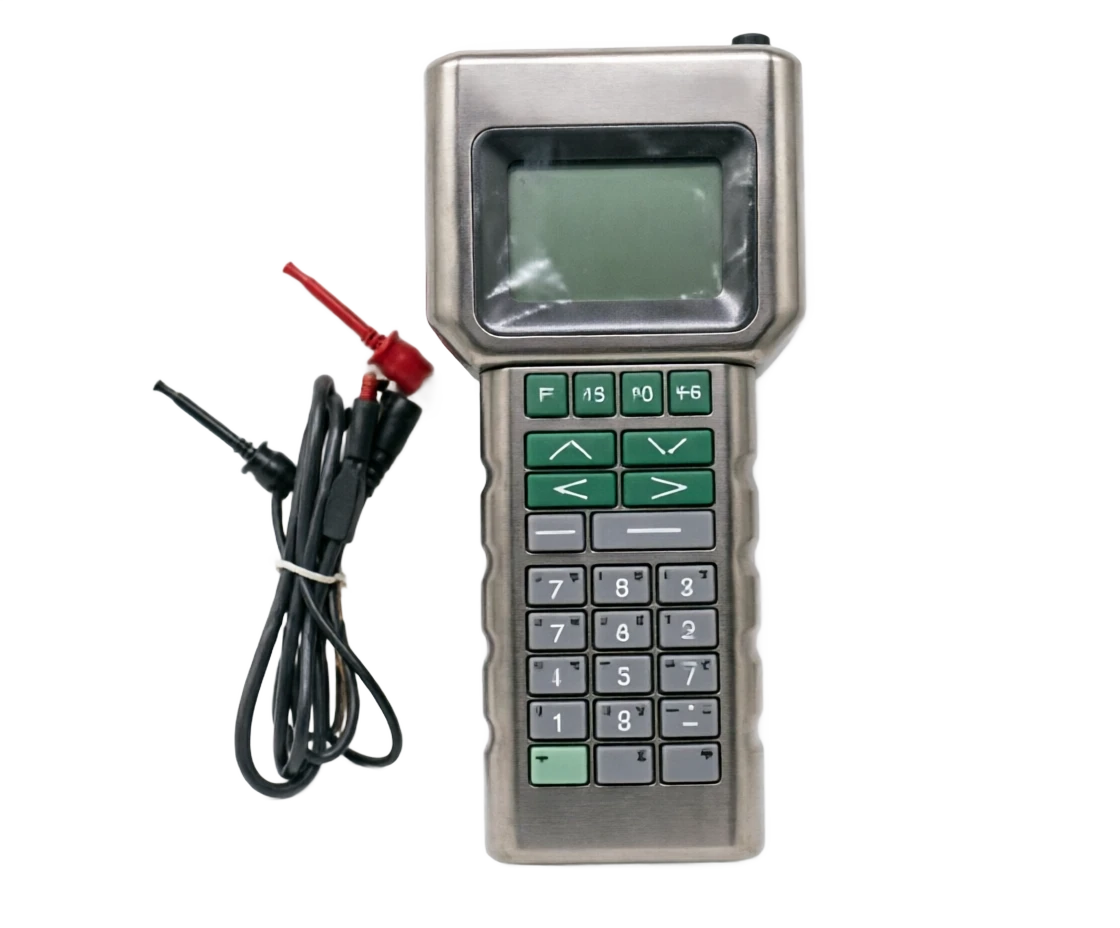
Smart Handheld
Operating principle
Smart hand mechanics.
(a) A core structure with "Performance/valve double-channel capture + Server magnification logic + Manual automatic hand-to-track": under automatic conditions, the signal given by the regulator to 4-20mA is taken in parallel with the rating received by the implementing agency, the MMU calculates deviation, the deviation drives the reverse or reverse output in direction when the deviation exceeds the dead zone, the valve is aligned to the given area, stops after entering the dead, and constitutes a "location-to-place" servo closed loop; Manually, panels (or bits) directly produce target valves, which are closed-ring driven valves; The tracking mechanism ensures that the output is undisturbed when hand / automatically switching.
- 01
1 · 4-20mA (automatic target) given by the given signal . / DCS; 250 standard loads blocked by input; breakline detection (<3.6mA determines break signal)
- 02
2 . Valve feedback input . Executing agency valve 4 - 20mA current feedback (second-line power circuit) or 0 - 1 k level feedback (old-style implementing agency); feedback breakout detection and quantum calibration (0% and 100%)
- 03
3 . Service magnification logic . deviation = given - valve; dead 0.5 ~ 5% groupable; deviation > + dead Zone Zoan rotation output; deviation < - dead Zoan Zoan invert output; entry to dead zone is stopped (interrupted drive to avoid frequent electrical outbursts)
- 04
4 • Relaying power output (AC) 220 V / 5 A level) or solid state relay / two-way controlled silicon output; positive and opposite sets of output electrical interlocks (hardware interlocks + software interlocks double-insure)
Structure
Smart hand-manufacturing. Structure.
The whole machine is embedded in a plate panel structure, dominated by 96 x 96 mm and 80 x 160 mm (diplining, easy to board), the front panel displays and the operator, the core consists of the master control plate and the power output panel, and the separation of power units (relays/solid-state relays) from the weak signal area is the focus of the structure design.
- 01
1 Frontboard . Double row LED display (main contour valve / sub-prescript, 0 ~ 100% equal scale); Hand / automatic switch (with protective shield to avoid error); Manually add / decrease the button or trigger; Status light (Auto/ Manual / Turning / Reverse / Alert)
- 02
2 . Master Board . MMU Runs servo magnification logic, hand-state machines and protection policy; dual channel ADC picks for valves; parameter EEPROM maintains power outages
- 03
3 . Power Output Panel . / / Reverse Relay (AC 220 V/ 5 A) or Solid State Relays; Hardware Interlocking Circuits; Separated from Main Control Board Light; Power Area Independent Dispersion and Gravity Distance Design
- 04
4 . Signal input area . Give 4 - 20mA input tip (250 input resistance, i.e. regulator standard load); Valve feedback input tip (4 - 20mA two-line power supply / bit-power incentive optional)
Application area
Smart hand-manufacturing • Application field
The complete description shows the technical sections.
- 01
Tests and equipment Large test valve manual operation and remote switching with remote soft hand-hand communication
- 02
Modes ..Construction of return ..points
- 03
Concort + Handheld + Electric Valve & PID Compressor (PART 50) output 4-20mA ⁇ Handheld server magnification ⁇ Electric Executor ⁇ Classic three pieces set; track wire guarantee no disturbance switch; manual on regulator failure disk
- 04
DCS + Handheld + Electric Valve · DCS Simulate 4-20mA ⁇ Handheld ⁇ Executing Agency; Handheld state and valves sent by communication • DCS sidewalk emergency when failure; MFT/ lock-to-lock manual logic
Selection Guide
Smart handman.
The complete description shows the technical sections.
Model Selection SELECT A MODEL
1 Model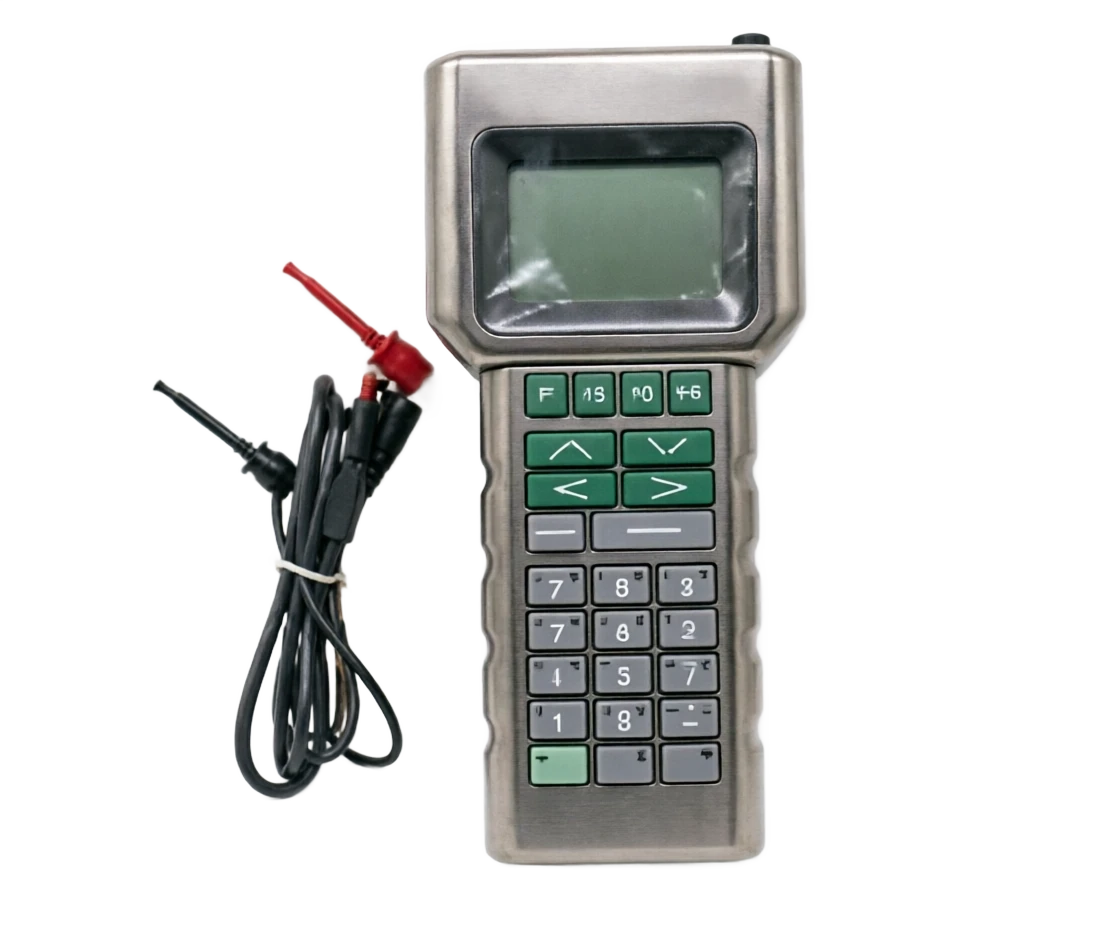
Smart Handheld Selection Support
Provide survey missions, media and installation conditions and obtain product configuration advice.
Contact us